3D Lane Detection from LiDAR
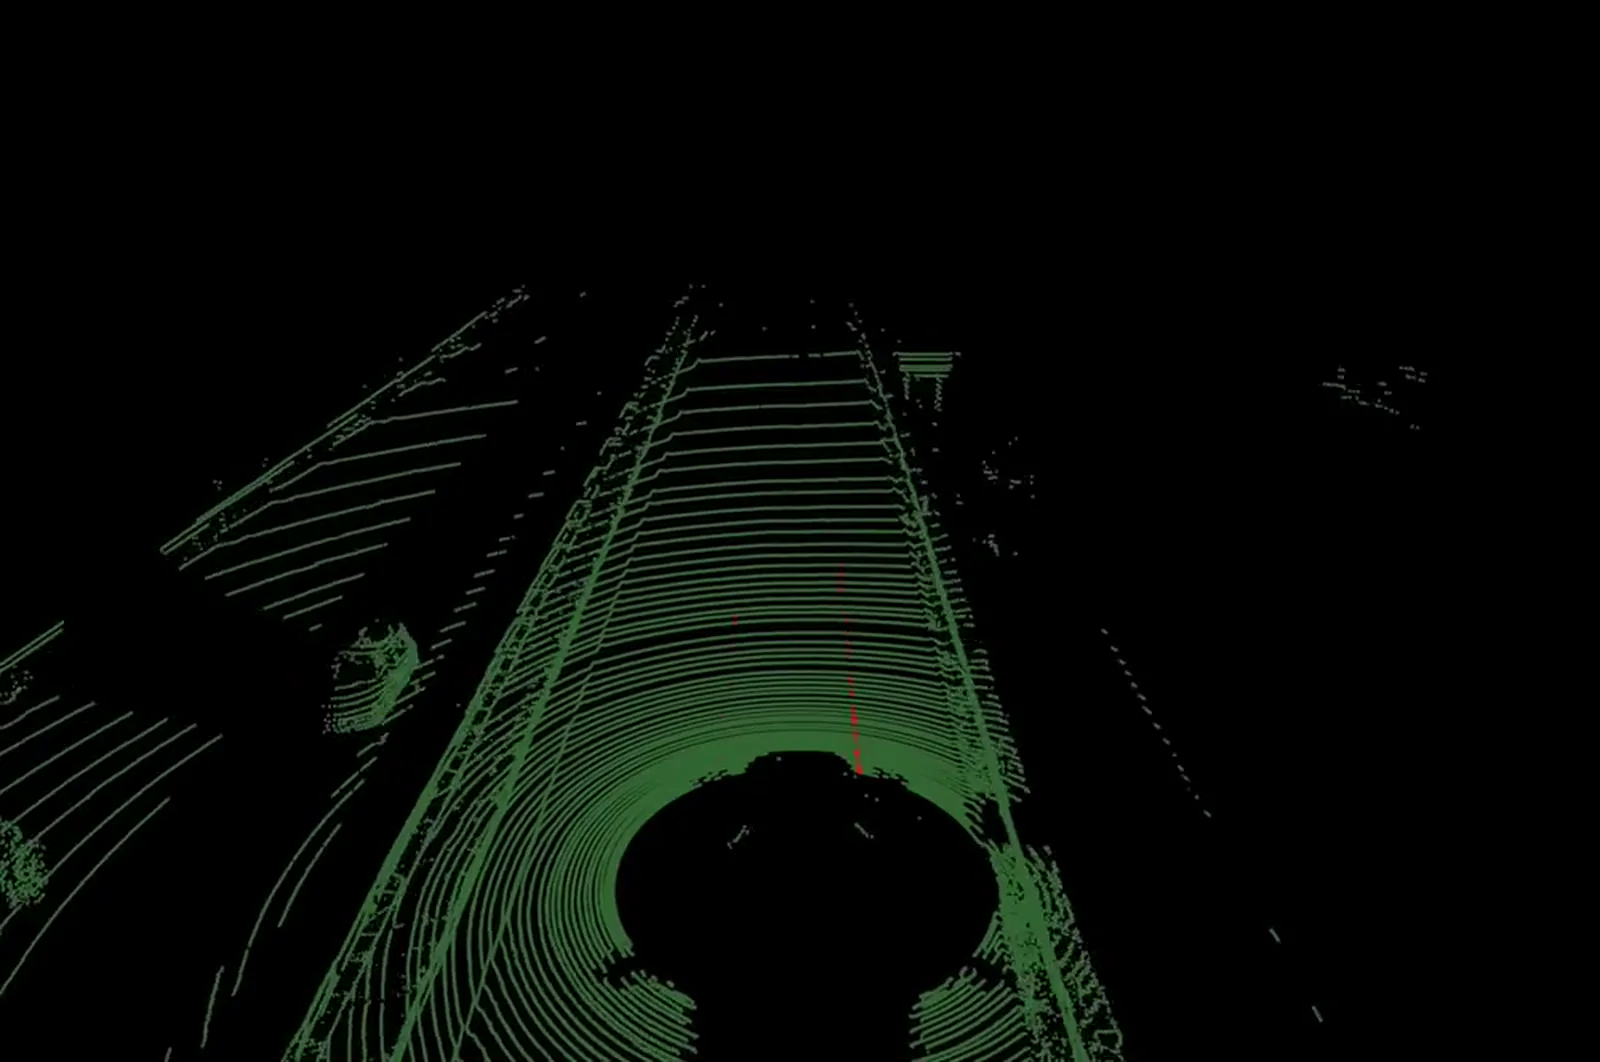
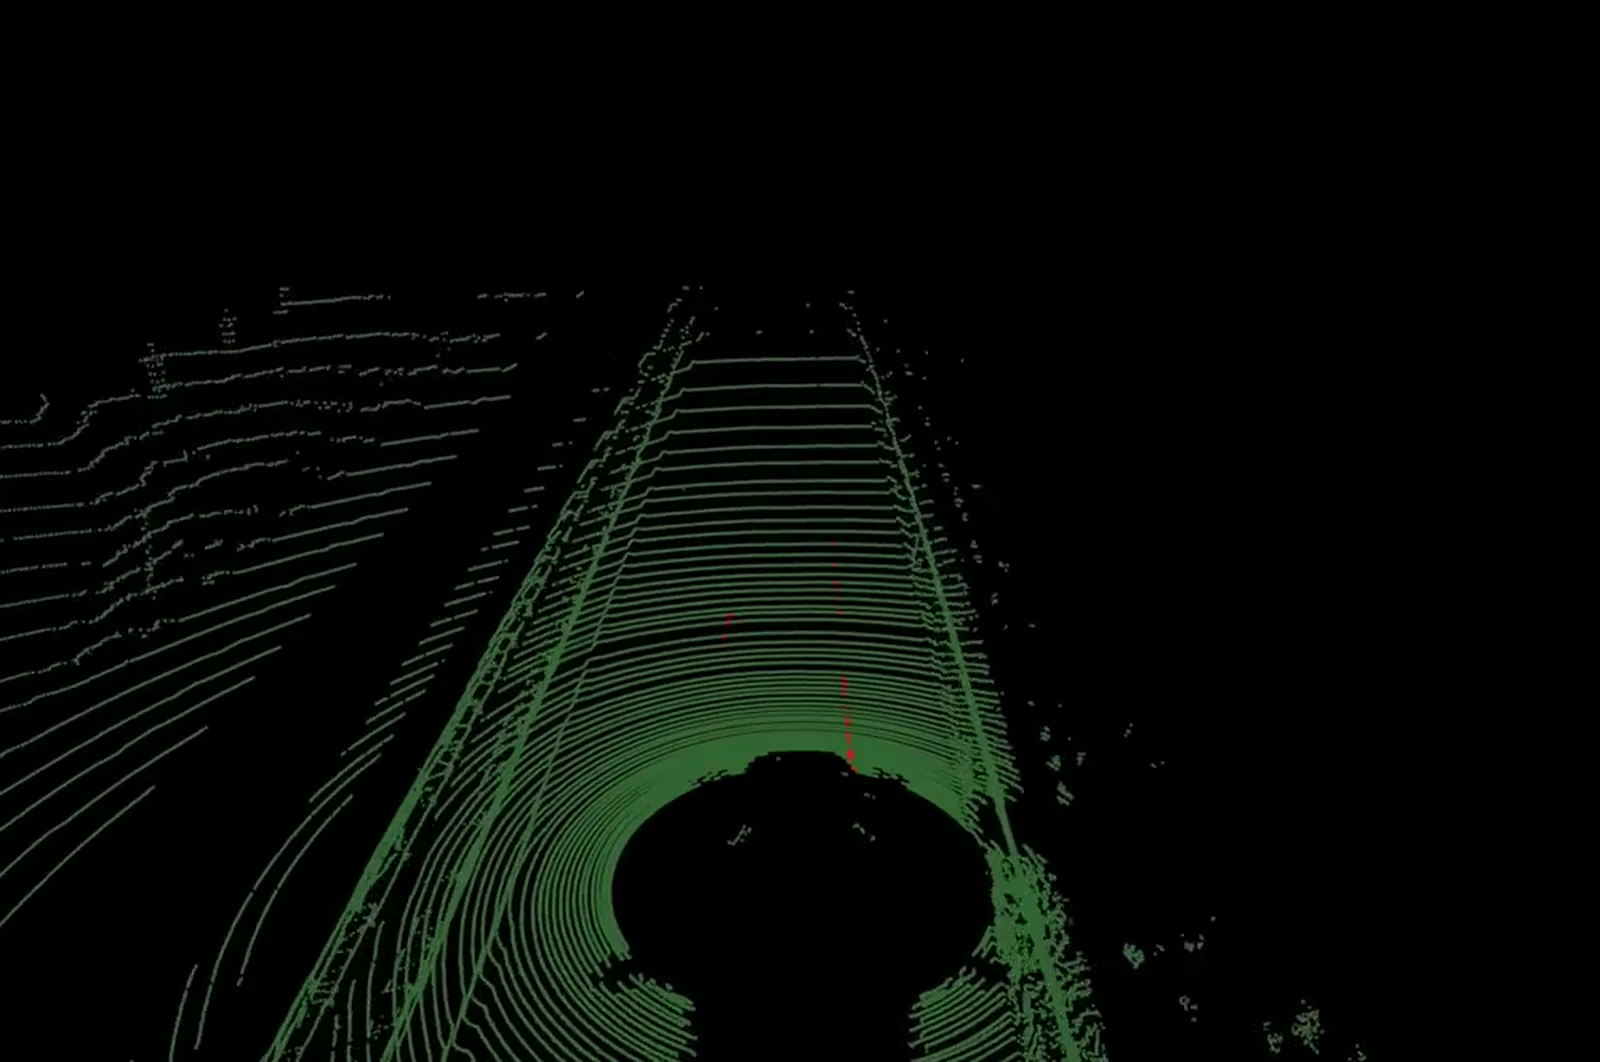
3D lanes lane lines extracted directly from the LiDAR point cloud.
- Client
- Confidential
- Year
- 2024
- Category
- Computer Vision
- Role
- Design + Build
- Timeline
- 4–5 weeks
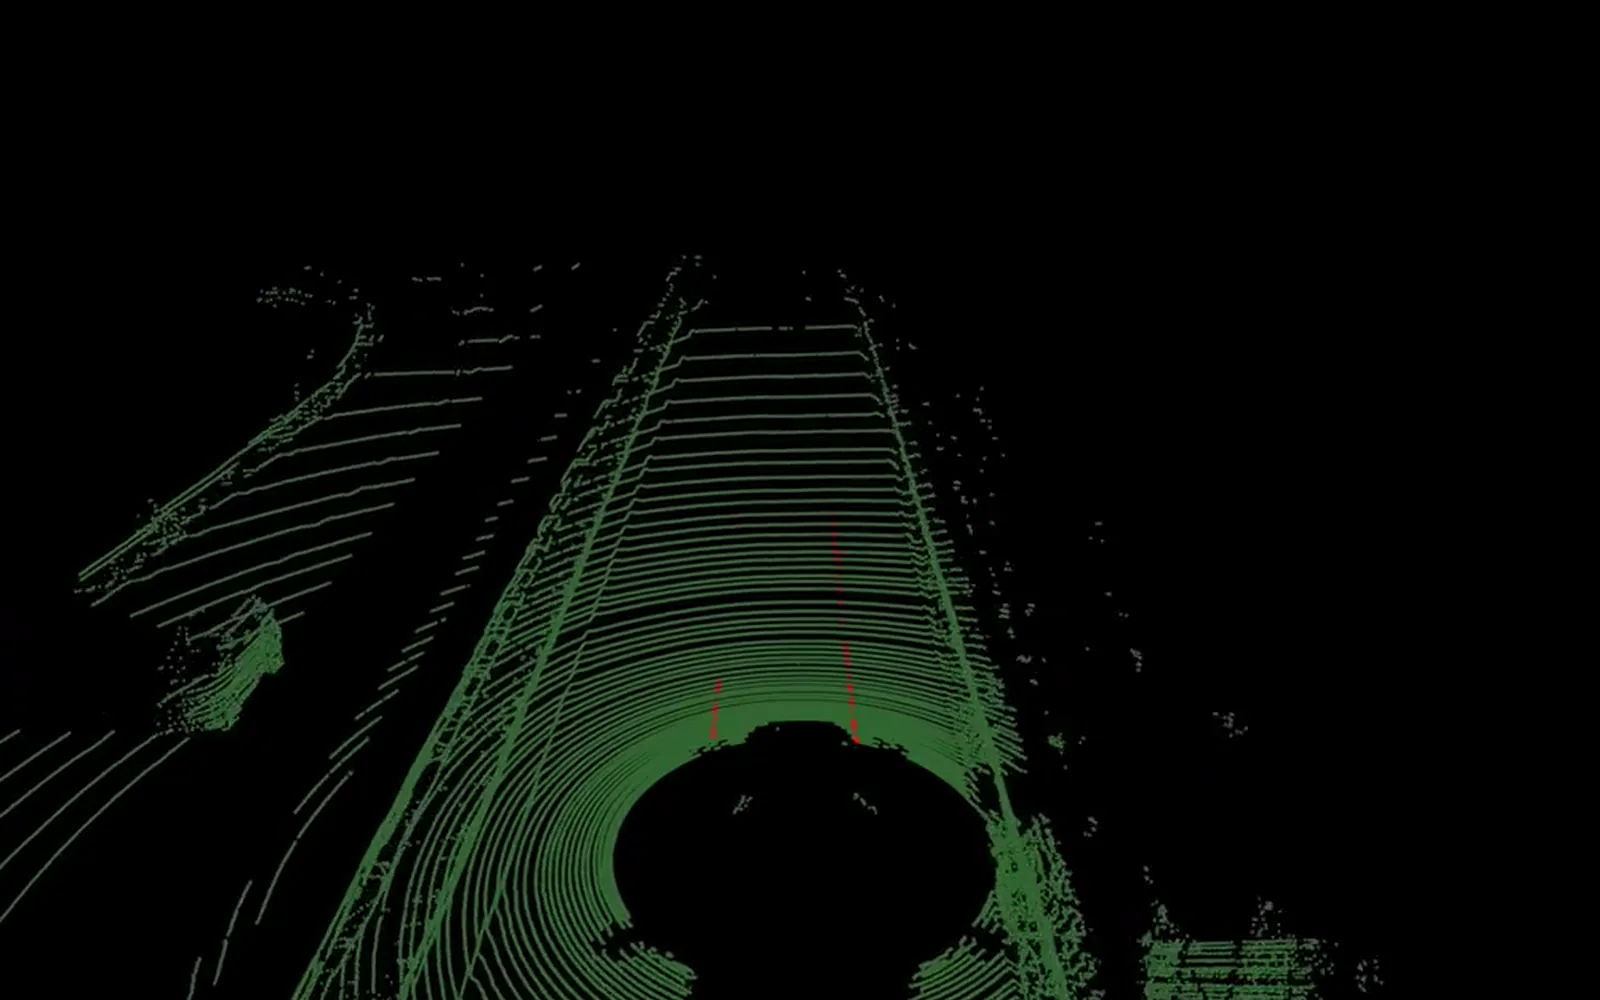
3D lanes lane lines extracted directly from the LiDAR point cloud.
Camera lane detection fails in the dark, in glare and in bad weather, exactly when a vehicle needs it most. LiDAR keeps working, but its point cloud is sparse and noisy.
A two-stage pipeline: an intensity-threshold pass pulls the most likely lane-line points out of the point cloud, then a region-of-interest pass tightens the result to the drivable corridor. Output is 3D lane geometry, not a 2D image overlay.
Lane geometry that holds up in conditions where a camera gives nothing, usable on its own or fused with vision.
Built with
We deliver what we commit.
We'll come back within 24 hours with honest feedback on scope, timeline and cost, whether or not we turn out to be the right fit.